Dimensional @dimensionalos
The open-source framework for agentic robotics. Program atoms, not bits. Join: https://t.co/TqYXsMY3On dimensional.org Joined June 2025-
Tweets159
-
Followers5K
-
Following0
-
Likes534

Is Jev is a game changer for robotics? We gave Jev a robot body and handed it complex tasks across navigation, spatial reasoning, and world geometry 120 different real + simulated tasks and environments benchmarking performance against Dimcode, Astra, Fable, Opus, and 5.6 We graded against speed, cost, tokens, # collisions, path quality Code, Data, and Paper dropping tomorrow. The results were surprising.
Awesome to be back in boston! If you’re in town drop by and see some robots.

Announcing our Gold sponsor challenges. Dimensional: Best Use of Dimensional 🏆 Prizes 🥇1st place: Unitree Go2 per team + interview opportunity for internship or full-time 🥈2nd place: $500 cash per team + interview opportunity for internship or full-time Elastic: Find the


Apply now: build.dimensional.org
Introducing the Dimensional Hardware Grant Program We’re giving away quadrupeds and arms to devs and creators to build with dimOS Deploy robot agents as easily as software Apply below, reply with your project ideas and we’ll fast track your application

As I leave SF after a short stay, I’m more excited to be a builder than ever. Had the fortune of visiting @fdotinc (thanks @ruslanjabari) and @dimensionalos (this is their current office). Really humbled by the level of talent here. This place is 🔥
DM us!
I'm hiring a head of storytelling to document our mission as we scale to 1000s of shipped robots and build the application layer for atoms Profound taste, technical knowledge, and end to end creative execution experience required After AGI only human stories remain
As someone coming from gamedev, something as simple as planning and executing motion on the arm to this day gives me a feeling of wonder. It’s essentially just an IK solver from which the joint angles are computed and then applied to the motors. Nothing new. But it moves physically! (robotics people may now laugh at me haha)
Started in this office a year ago with 2 of us Onto the next with 25 people and 50 robots Huge things incoming


🏆 1st place, Open Source @lenslist AR as an interface for robot navigation. Give move-to commands using hands or voice and the robot moves there autonomously. Works in a variety of environments and conditions. Stock firmware on the @UnitreeRobotics dog. @dimensionalos powers the entire navigation stack with dynamic pathing and LiDAR streaming. UI and interactions on @specs AR Glasses. I’m already working on v2.0 with VPS support (@multiset_ai) to reduce drift on longer distances (>5m) and cleaner DimOS integration. Gotta say, making this is a bit of a rollercoaster as it’s genuinely hard but also I just want it to exist and seeing it work is the most cool and rewarding thing ever. Repo: github.com/V4C38/spectacl…
@Alpha10six let's go, let us know if you need any help with integration🚀
started with 2 people and 2 robots a year ago, now 25 people and 50 robots we’re officially out of space, so join us this friday to celebrate the end of an era and wreck some hardware

Agent autoresearch as the new RL?? 🤖🚀
Agent autoresearch on robot navigation and control Using infinite procedural generated scenes to tune trajectory control, and then rollout in mujoco to match real world physics Shipping open source next week, supports both arm and humanoid trajectory.


Fire! More platforms running dimOS

Two days ago VECTOR was a homemade mecanum rover with a Jetson Orin Nano and no brain. Today it explored my workshop on its own. What I did, step by step: – wrote a dimOS blueprint for it (@dimensionalos open source robot OS), so their cockpit, 3D viewer and nav stack run on it
the fleet is growing past 1000. we’re giving away 50 robot dogs to developers just because. drop your github, and i’ll send u an application. get building. repo below.
Every computing shift has produced a new kind of engineer, this one will too. We wrote about who that person is and what we are building for them. x.com/i/article/2087…
drop by @dimensionalos room at @sanctuaryparc museum and operate robot arm in sf!

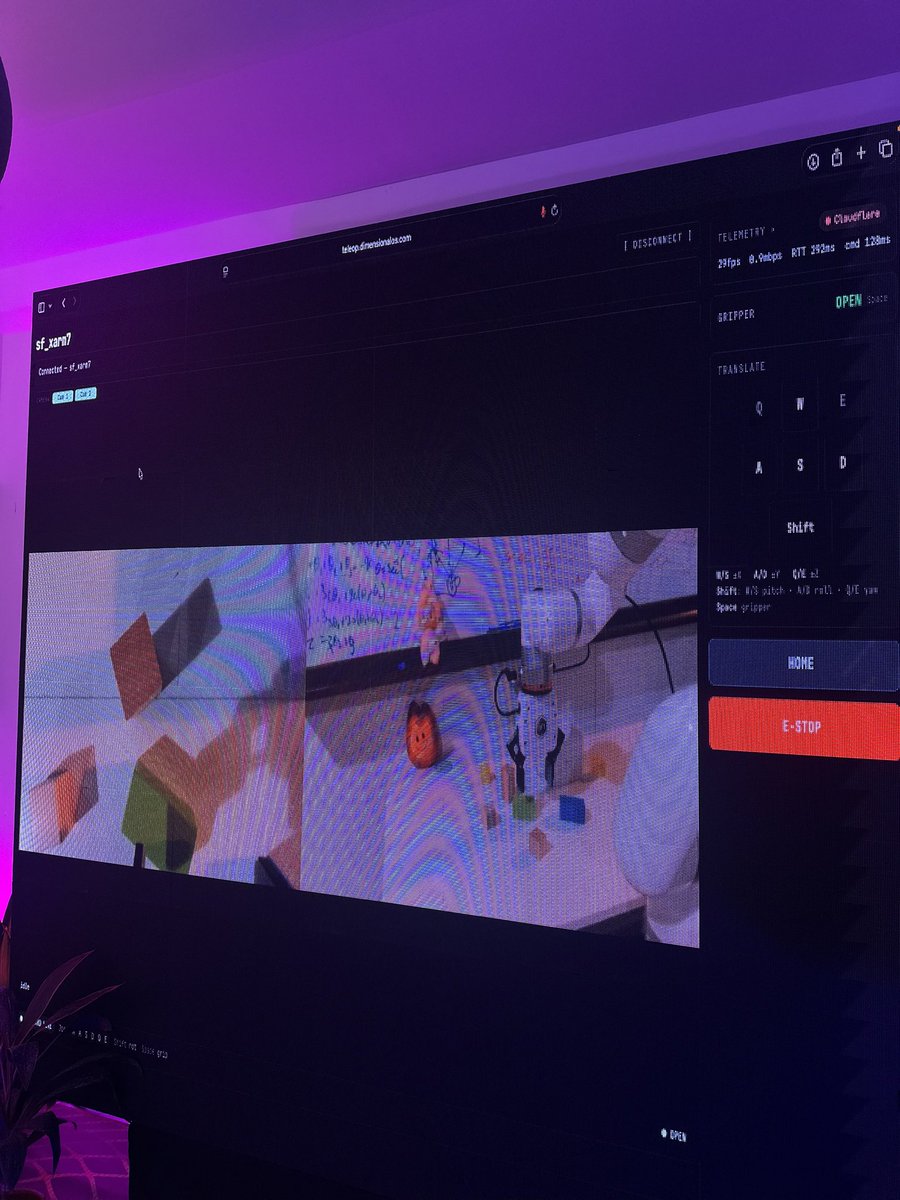


From the technoromantics of 3rd block & @basecampblr, a @sanctuaryparc museum, tomorrow.


Local path planning week. A few cool steps - wrote inefficienet path planning of my dreams, full depth first search with orientations, autoresearched a very fast algo with same performance (no surprises it's A*) - recorded locomotion model I/O and ground position on the robot, replayed it in mujoco, used optuna to tune to match the way a real body behaves - implemented a judge for trajectory (maximum speed without colisions, autoresearched the control algo


The cameras scan your back, YOLO11-pose + YOLOE models segment the scan live into zones: shoulders, upper back, lower back. Then the two arms with padded end effectors work through, coordinating on a real person. If a weekend hackathon is enough to get a working demo, imagine what a team could ship in a couple of weeks.
This massage robot was built in 72 hours with dimOS by students who had never worked with a robot before. An AgileX Nero dual arm with binocular cameras that maps your back and gives you a two handed massage.

catizcat @catizcat
5 Followers 155 Following
Saber Asgharnejad @s_asgharnejad
1K Followers 4K Following “Everything Unlimited” 🦾 PCB+Components+Assembly

Jarvis Pang - GNAP Me... @ChiefJarv
2K Followers 3K Following 🚀 I turn coaches & speakers into media-verified authorities. GNAP Media | PR, Press, Google Knowledge Panels. DM me “FEATURE” to get published.

Chakradhari shiva @chakradharisiv
64 Followers 1K Following robotics++; Incoming @JohnsHopkins (LCSR) Spring'27
Roshan Kamat 🇮🇳 @_roshan_kamat_
10 Followers 71 Following 22 Engineer, building https://t.co/SyaHAM1Lm4
Varun @varun_mara
1K Followers 2K Following
Jahangeer (Jay) Ansar... @ja3eth
432 Followers 2K Following Call me Jay. #Web3 #DeFi #AI, marketer, business developer, consultant, advisor, lifelong learner and futurist. 🔕🤖 💻☕🍊🤖𐙚
Muhsinun Chowdhury @MuhsinunC
60 Followers 152 Following Used to hustle fidget spinners, now I hustle your mom
Abel Simon @inferencexai
9 Followers 287 Following Building https://t.co/ERj3RmPvYl - Intelligent issue & ticket resolution
Ahmet Karapinar @ahmetkdev
297 Followers 3K Following AI for Factories in 21st century SWE @ManevaAI , prev @IBMCanada
Dangel | Galaxyhub La... @seenfinity
14K Followers 1K Following Building @GalaxyhubAI | @Voightxyz | x3 Hackathon Winner | Member of @LaFamilia_so | JET Pilot member @JET_EUROPA_

Yilty @loytr_9
23 Followers 3K Following
Lee Daryl Yang @leedarylyang
7 Followers 593 Following
MuskyElon @MuskilyElon
6 Followers 2K Following
char @rohanxparmar
42 Followers 284 Following
SPANYO @SEE_SPAN_TV
16 Followers 148 Following Leveling up in real estate deals, trading the charts, diving deep into AI innovation, and crushing games when the markets close.
Tejaswi Karasani @TKarasani
515 Followers 4K Following View are my own. Software Engineer @intel Intern'21 @intel @Outreachy Intern'20 @Mozilla #FinanciallyIndependent

Jovian Shilton Dsouza @DsouzaJovian
1K Followers 2K Following AI web3 Hardware guy | Building @moltypet | Member @SuperteamIN
Shehryar Saroya @SaroyaShehryar
146 Followers 1K Following CEO @MovingAtomsLab (YC S26) - World Models for Robots Prev: ML @TikTok core recsys · Maths @Oxford.
Vishal Singh @VishalSing26731
0 Followers 24 Following
Vivek Phalak @vphalak
61 Followers 653 Following Entrepreneur | CTO/ Co-founder Shoptimize | Data Engineering, AI | ex-Oracle | CMU Alum
Praveen Sridhar @psbots
1K Followers 6K Following Machine Learning Engineer building in the healthcare and insurance space. Co-founder of @tinkerhub, a non-profit educational initiative.
Vinay Rao @wizardofid
2K Followers 1K Following Reforming the design + innovation industry. Co-Founder BangDesign*. Enabled $500Mn in new revenue 75000+km bicycling

Jaspal Singh @JaspalS44414885
15 Followers 2K Following

Rajbalaji V @rajships
38 Followers 141 Following Building Dexops | @fdotinc Canopy | Robot Learning & physical ai
satvik @xSatvik
331 Followers 820 Following cs undergrad | robot learning | agents @IBM, prev intern IBM, @ISRO dms open
Harrish Ayyanar @harrishayy
3 Followers 77 Following Robotics and AI @ UCL | Cisco, Prev. General Learning (YC F24) Researching :/
Tejesh Kunapareddy @arjun7n9s
3 Followers 86 Following
pun. life. @mindkhichdi
865 Followers 5K Following Finding Nemo. Finding Data. Chief Pun Officer of life. No code,Low code


Sudhin Karki @SudhinKarki
67 Followers 445 Following AI Engineer/CEO @HimalByte | LLMs, Systems, Robotics | Sharing builds & fails| Nepal-based indie hacker| Building DMKit | https://t.co/HewQrHk5hx
Serg @FraudGnosis
2K Followers 4K Following ☀️🌊 SoCal born x raised ▶️usmc vet now in tech freelancing + ⏩️BUILDING random & bespoke stuff w/ai +3D ⏺️I post tech/ai, sports, ufo/phenomena
Vlad (Moving Atoms ar... @CosmicDude3000
932 Followers 515 Following Tech and Finance (money) enjoyer. coFounder @YumiFinance
Marco @menrva33
2K Followers 6K Following Owner | Mentor | Investor 500+ construction & sport projects Drones. AI. Robotics. CV. 3DGS. Phygital | Tricorder | AgriT | Ethics & Philosophy | 🇩🇪 🇮🇹 🇺🇸
Abhimanyu R B @AbhimanyuRB2
64 Followers 774 Following Founder @ AnukritiAI 🧬 Simulating drug safety before clinical trials AWS 10,000 AIdeas Innovation Award Winner Base44 Cohort 1 | Zerobase S4
Rational Aussie @rationalaussie
37K Followers 7K Following Humans are fungible compute. I write about economics and AI. Fix the money, fix the world. #Bitcoin
Florian Clanet 👨�... @FlolightC
2K Followers 4K Following 💻Prototype Architect @awscloud 🌥Cloud, GenAI/AIML enthusiast 🎚Stage lighting passionate 📌Opinions here my own ☄ he / him Follow me to grow together!
The Ponderer @abraham_loner
145 Followers 249 Following I like Computers and Robots product eng @Daya_hq.Shipping @coral_xch, ex: @revokecash


Simon @SimiStern
2K Followers 3K Following world building & frontier futurism @ns alumn @superteamCAN member https://t.co/Uzttv2NhzoYou might like