

4/4 @MartianArray
Joined December 2024-
Tweets179
-
Followers46
-
Following294
-
Likes33
Topology Optimization Effect of Legged Robot Leg Structure Based on Fusion 360


The ROBOCON competition in mainland China this year concluded successfully from July 9 to July 17. This marks my first year participating in the event as both a referee and a staff member.


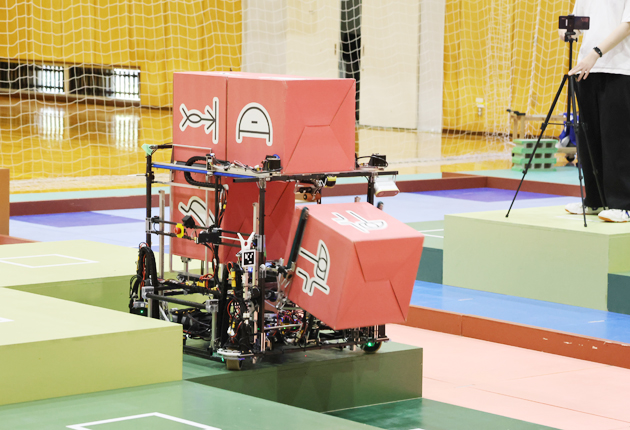
あす学生ロボコン 王座奪還へ! 豊橋技術科学大学開学50周年に10度目の優勝を ロボット競技会「NHK学生ロボコン」は14日、東京都内で開かれる。 昨年、4連覇を逃した豊橋技術科学大学ロボコン同好会にとって、雪辱を果たして王座を奪還し… tonichi.net/news/index.php…
This is an interesting paper I saw at ICRA 2026. It talks about how to make a cost-effective 22 DOF robotic hand and goes into a lot of details on how to assemble it and configure it into different configurations.


Boston Dynamics mostró recientemente que Atlas realizó un potente backflip con una precisión notable. El robot aterrizó limpiamente sobre sus dedos de los pies e inmediatamente se lanzó a un segundo backflip. Esta capacidad avanzada es impulsada por un sistema de aprendizaje de todo el cuerpo desarrollado por el Instituto RAI y desplegado por Boston Dynamics.


asked claude fable 5 to design a qdd actuator it also animated the gearbox and inspected collisions as part of the validation loop ~ 30 minutes / 400k tokens

Taking part in the China Regional Exchange Competition of the National University Robot Contest ROBOCON held in Guangzhou, China.


CyberGear 、高速カリッカリでパネェ
Una foto entra. Un archivo CAD sale. MIT acaba de liberar GenCAD: un modelo que convierte la imagen de una pieza mecánica en un programa CAD paramétrico editable. No es text-to-image para hacer renders bonitos. Es image-to-CAD para tocar una parte mucho más cara del mundo físico: diseño, prototipado y fabricación. La primera víctima no es SolidWorks. Es el junior que pasaba sus días traduciendo bocetos en geometría técnica. Open source. Se llama GenCAD.
#CVPR2026 Can frontier LLMs write PhD-level 3D vision code? We introduce GeoCodeBench, a benchmark that asks models to read real 3D geometric vision papers and implement core functions. Best result so far: GPT-5 reaches only 36.6%. This suggests that scientific coding in 3D vision remains far from solved. Paper: arxiv.org/pdf/2603.30038 Project: geocodebench.github.io
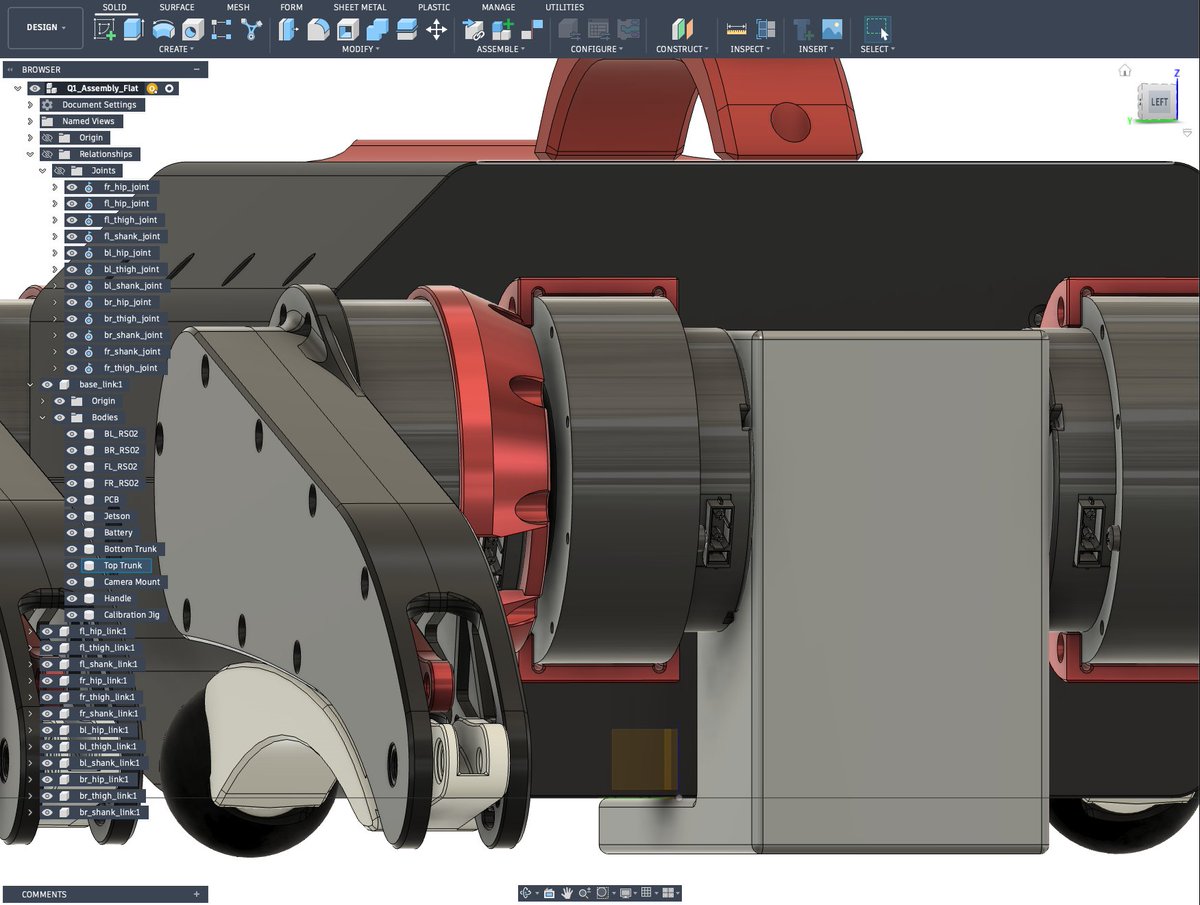
Trying out a new calibration jig that takes care of the calf position as well

When building a custom robot, it is helpful if the same joint position values represent the same physical pose across the entire pipeline: CAD, URDF/MJCF, RL/simulator, robot runtime software, and the motor-controller firmware. Debugging is easier when there are no sign tables or

Video “A” vs. video “B” Same robot body, But two different brains. Do you see the difference? Model-based control vs. Learning-based control @RoMeLaUCLA
Our External Force-Guided Curriculum Learning (EFGCL) enables robots to learn various dynamic motions with simple reward functions. The method is inspired by "spotting" in gymnastics, where a coach physically supports an athlete during training. Here's how it works👇

BYD Leopard Bao 8 - redefine off-road

2 notable changes in new Wuji hand (right) The 4-bar linkage at the MCP is gone (yellow) The IP joint axes now intersect the phalanx centerline, hence worm-gears out, bevel gears in This affords mechanical back drivability and robustness
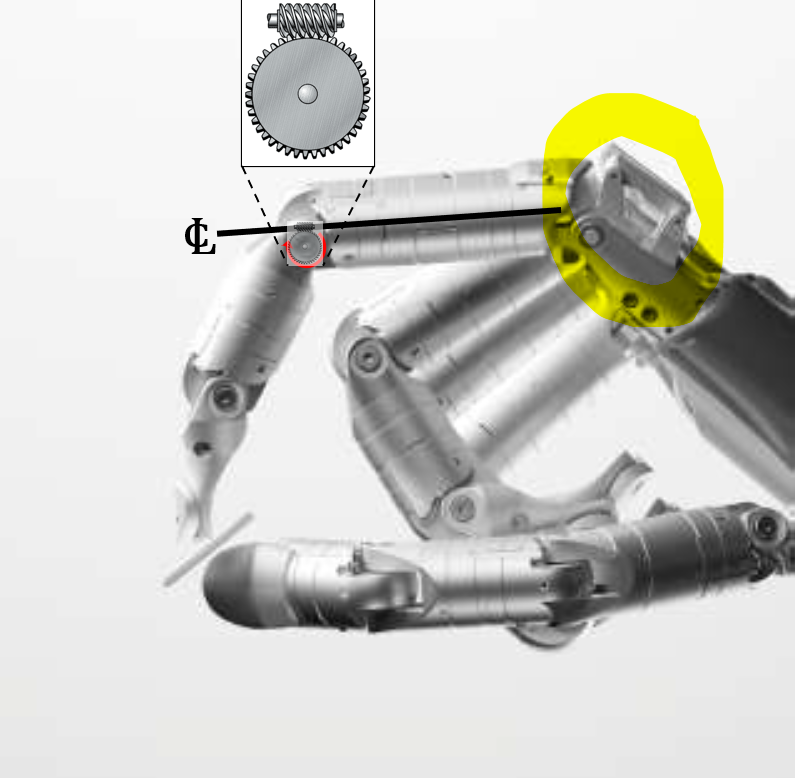


After 8 months, Wuji Hand fully upgraded. Wuji Hand 2 -- Creating for elegance, redefining the dexterous. Learn more: wuji.tech Sales Inquiries: [email protected] Careers: [email protected] #wujitech #wujihand #Robotics #DexterousHand #EmbodiedAI #PhysicalAI


makiguy(コミュ障�... @makiguy2
439 Followers 640 Following 立川74th → 信大22T4 → 東北大学大学院ロボティクス専攻 東京→長野→宮城 卓球🏓 学ロボ24~25
Om @omgAfc27
6 Followers 81 Following

Hamburg @hambububububu
604 Followers 757 Following 東のNITTC 4J /関東春ロボコン'24「桃花飾組」TL・機構設計/高専ロボコン'24「Astarium」ピット・R1設計/関東春ロボコン'25「鵥」チームメンバー・機構設計/高専ロボコン'25「明修羅」ピット・機構設計/高専ロボコン'26「京鴎」ピット・設計
KNT @KNT718630251
486 Followers 538 Following 福島高専ロボット技術研究会🤖/機械班5年/福島高専「白虎」チームリーダー、足回り操縦 /2025廃炉創造ロボコン

Ryu @Ryu_roboken39
1K Followers 5K Following 23+1s/成人済/技術・雑多垢/ロボコニスト/推しはミク/モタスポと野球観戦,VALORANTが好き/学マス,スタレやってます/ベッテルのファン/Valo垢→@ryu_valo21 /GRCC機械 Bチーム
ウドンコリー... @udoncori0213
262 Followers 384 Following 旭川21s ロボコン2024ベスト4 「LazuRite」 2025全国優勝「天旋」 非金属マスター

グロタン @grotan_rob
2K Followers 3K Following NITIC→TUAT 高専ロボコン2022~2025/ CORE1_2025~2027/ 廃炉創造ロボコン10.11/ @robocon_TRU @inct_robocoso
ぃもけんぴ@茨�... @hosiimokenpi
751 Followers 2K Following NITIC / #kosen23s / ロボコン/ 機械屋 / 舞浜 / 吹奏楽🎷/ A1mini / PA / 照明にも興味あり / 今はニコン党

Sourabh @sourabhrbhosale
37 Followers 309 Following

Gotoo @Gotoo4251
93 Followers 1K Following

Aplabo @Aplabo21875
65 Followers 1K Following
ぶたん @Butane_4
1K Followers 2K Following ♰ゆら~を極める♰ 茨城高専22s→富山大学 2026茨城A 全力応援ニキ 交ロボ2024/彩雲(べこべこちんちんあんこう) リーダー,機構 NHK2024 /銀河鉄道αiR_liNe リーダー,機構
うぇるす / wellS @Well5SS
356 Followers 413 Following 元Robohan(@Robohan_) / 阪大 応理 機械→機械動力学の研 / 学ロボ2025 / アイコン→@Well5SS / ロボコンとアニメとゲームの渾沌 /

kaze akatsuki @akatsuki__kaze
7 Followers 48 Following team member of MTI(FJUT robotic lab).Green hand in Computer Vision Recognition.
Woootwo Europa @europa_woodtwo
117 Followers 105 Following Big Hentai mechanism designer 2024,2025,2026 B4 成就 帅是一辈子的事(2025) 成就 R1 & R2 robot designer for 2026 Robocon(2026)


つくし @GlassesTukushi
225 Followers 767 Following


Lain @Lain_Ego0
3K Followers 1K Following CN.Robotic/Locomotion 致力于新工科教育科普与助力机器人开发者入门,希望对你有帮助。 长期活跃于深圳,欢迎coffee。
セン @Sen1575
1K Followers 1K Following センです*。NNCT→Nagaoka UT 25s 編入 高専ロボコンOB 2021→2024 学ロボ2026 運営班 渉外担当 Phoenix Robots所属 全ロボ幹事団OB 21,22 #ロボコン #高専ロボコンOB 回路班もどき 楽死む


あいす⚙️🌙 @ice2alice
754 Followers 553 Following #kosen23s よわよわロボコニストとラブライブのオタクをしている百合豚です たまに(学マス、シャニマス、バンドリ、トゲトゲ)
gaku @gaku__raku
1K Followers 1K Following NHKロボコン 荒川 2015~19→豊橋 21🏹→競技補助・副審22~ / キャチロボ2022, 23 / 魔改造の夜🐊 / 知ロボ2025🐮
えだまめ @mimimi_eng
355 Followers 420 Following M1 学ロボ‘24🌾 設計班長・PM R2設計 / #ATTRACTS miniministep PL @step_minimini
かどや @Kadoya__
1K Followers 2K Following 阪大 工環エネM2/オナー大学院P/関西春ロボ運営(@kansai_robocon) 代表/Robohan 21er/KINKI KNIGHTS/キタニタツヤや明くる夜の羊が好きです
トリ @pC759
874 Followers 1K Following TUAT ロボット研究会R.U.R B4 / RC25 TeamLeader · R1&R2 Mechanical Engineer
CuO @nure_zokin
284 Followers 239 Following ロボコンズ27 ひょ '22, '23 豊田Aチームリーダー/ '24, '25 学ロボ 雑務と設計/ '24, '25 CoREjp_TMC/ Scrambleの幽霊会員(CoRE担当?)
【非公式】Chi-Ro... @robot_chi
251 Followers 297 Following @Ti_Robot → NAGOYA SHACHIHOKO (@RoboMaster8)/ TTI Grad Student/ ARチィチィ2026/ 主に奇怪班
3歳児 @1692spear
461 Followers 846 Following


LightOrigins @LightOrigins_
1K Followers 17 Following Light Origins brings foundation-model intelligence into the physical world so machines can perceive, reason, and act.
Pollen Robotics @pollenrobotics
19K Followers 224 Following Building open source robots made by open minded humans to explore real-world applications. @Huggingface family Join our community: https://t.co/KFG0LopcZt

工学院大学ロボ... @krp_kouhou
2K Followers 558 Following こちらは工学院大学のロボットプロジェクト、通称”KRP”の公式アカウントです!新入部員大歓迎中っ!!!質問はマシュマロ 連絡はDM、公式LINEからどうぞ! https://t.co/fdwj8n3hlc #春から工学院 #春から工学院大学 #KRP
Kevin Wood | Robotics... @KWRoboticsAI
900 Followers 1K Following 10+ years in robotics, AI/Ml, computer vision and controls. Subscribe to my YouTube (75k)👇
Ryo ; Toin Sigma - Th... @ryo_robot14
599 Followers 275 Following RoboCup 2025 Soccer Infrared 日本4位 RoboCup 2019-2027 #robocup2025 #thrive2027 @RCJ_Thrive contact : DM / [email protected] 医療ロボティクス l 機械・回路・制御をつなぐロボット開発
工学院大学学生... @kogakuinracing
460 Followers 496 Following 工学院大学レーシングチーム KRTの新歓用アカウントです!大学からなにかを始めたい方、車・バイクが好きな方、ものづくりに興味がある方大歓迎!随時紹介情報を発信します!質問はどんな事でも受け付けます👍お気軽へDMへどうぞ!#春から工学院大学 #すごくすごく1年生に来て欲しい ⇒@kogakuinrace
CopyRebeldia @CopyRebeldia
155K Followers 118 Following El futuro tiene mucho que ofrecer. IA · Tecnología · Robótica [email protected]
Yuhang Hu @Yuhang__Hu
2K Followers 42 Following AheadForm founder/CEO/CTO Ph.D. (Columbia University) Robotics&AI
Donald J. Trump @realDonaldTrump
111.9M Followers 53 Following 45th & 47th President of the United States of America🇺🇸

Commentary Donald J. ... @TrumpTruthOnX
647K Followers 0 Following Trump Truth Posts On X within 1 minute while the others are still asleep. Commentary, not associated with President Trump.

The Humanoid Hub @TheHumanoidHub
116K Followers 1K Following Humanoid Robots: Tech, Business, and Social Dynamics. Click the “𝕊𝕦𝕓𝕤𝕔𝕣𝕚𝕓𝕖” button on the profile to support. Run by @dev_and_
Zhenjia Xu @Zhenjia_Xu
2K Followers 100 Following Roboticist @ Genesis AI | Prev. Research Scientist @ Nvidia GEAR Group | CS PhD @ Columbia University
Matt Freed @mattfreed
8K Followers 1K Following Vicious robotic arms dealer @tetradynamics | Reindustrialist & prev co-founder @kscalelabs
Genesis AI @gs_ai_
13K Followers 0 Following Genesis AI is a global full-stack robotics company building general-purpose robots with human-level intelligence.
Kanade @Kanade___1214
2K Followers 1K Following OOEDO SAMURAI キャプテン 回路・制御エンジニア RoboMaster 世界大会二年連続出場 RMUC2024 RMUL2025 高専ロボコン/ロボカップ 2020〜2023
Anyi Rao @raoanyi
2K Followers 981 Following Assistant Professor @HKUST | AI for Creativity | ex @Stanford @Meta @RealityLabs @UofT | Works #ControlNet #AnimateDiff @cveu_workshop
Tairan He @TairanHe99
16K Followers 1K Following Researcher @OpenAI. Prev: PhD @CMU_Robotics @NVIDIA @MSFTResearch @sjtu1896 | All Opinions are My Own
Andrew Ng @AndrewYNg
1.9M Followers 1K Following Co-Founder of Coursera; Stanford CS adjunct faculty. Former head of Baidu AI Group/Google Brain. #ai #machinelearning, #deeplearning #MOOCs
Hugging Face @huggingface
802K Followers 227 Following The AI community building the future. https://t.co/TpiXQMQ9rZ
General Autonomy @GeneralAutonomy
5K Followers 7 Following physical labour is dead! long live physical labour!

Huazhe Harry Xu @HarryXu12
6K Followers 990 Following Hi, I am the founder of @PokeBot_Global. I like RL, robots, and video games:) I am an Assistant Prof at Tsinghua; Postdoc at Stanford; Ph.D. at Berkeley
JunLi Ren @junli_r84995
349 Followers 271 Following PHD Candidate @HKU MMLab, currently visiting @UCBerkeley , undergrad and master @Tsinghua_Uni.
Xiao Chen @XiaoChen_Twi
535 Followers 1K Following Ph.D. Student @ MMLab, @CUHK_official | B.Eng.@ZJU_China |Computer Vision & Robotics
OpenDriveLab @OpenDriveLab
2K Followers 67 Following Official account for OpenDriveLab @hkuniversity and Beyond. We do cutting-edge research in Robotics, Autonomous Driving. Email: [email protected]
Stanford HAI @StanfordHAI
109K Followers 605 Following The official account of the @Stanford Institute for Human-Centered AI, advancing AI research, education, policy, and practice to improve the human condition.
Fei-Fei Li @drfeifei
1.1M Followers 1K Following Cofounder/CEO @theworldlabs, Prof (CS @Stanford), Co-Director @StanfordHAI, #AI #SpatialIntelligence #GenAI #computervision #robotics #AI-healthcare
Robotics Papers @OWW
3K Followers 2 Following New Robotics papers from https://t.co/QghHeRjSAH: robotics. Thank you to arXiv for use of its open access interoperability.
Masa - D1 Humanoid �... @masa_zeals
19K Followers 666 Following CEO of ZEALS, Omakase Robotics Building D1, a compact humanoid built in Japan. 準国産コンパクトヒューマノイド「D1」開発🦾 採用中: https://t.co/9gdDtpm9z5 @d1_humanoid


Siyuan Huang @siyuanhuang95
5K Followers 438 Following Research Scientist at BIGAI, Director of Center for Embodied AI and Robotics. Ph.D. in Statistics from @UCLA. Former intern at @DeepMind and @MetaAI.
Zhengyi “Zen” Luo @zhengyiluo
6K Followers 1K Following Research Scientist, GEAR @NvidiaAI | PhD @CMU_Robotics | Builder @CirkitDesign | CS @penn Opinions are my own.
Carlo Sferrazza @carlo_sferrazza
3K Followers 348 Following MTS at @amazon FAR. Postdoc @berkeley_ai. PhD @eth_en. Robotics, Artificial Intelligence, Humanoids, Tactile Sensing.
Zhen Wu @zhenkirito123
2K Followers 409 Following Amazon FAR (Frontier AI & Robotics). CS @Stanford. Humanoid Robots & Character Animation 🤖
Ronald van Loon @Ronald_vanLoon
356K Followers 163K Following Helping AI driven companies generate value•Top10Influencer #AI #BigData #DataScience #IoT #MachineLearning #Analytics #Cloud
Harrison Kinsley @Sentdex
111K Followers 385 Following gpus and tractors. Neural networks from Scratch book: https://t.co/hyMkWyUP7R https://t.co/8WGZRkUGsn
🐹はぃ꙼̈き゚... @hogelungfish
1K Followers 698 Following 石巻高➞ 阪大様大学 Mech専攻 D4 | 公式垢@hogelungfish , RAM専垢@hogelungfish_, 監視垢@hogelungfish_BK | 🎦https://t.co/BfamFHjm5I ⌨️https://t.co/iDGa7Haui3

朴秀明(Shumei Bo... @BokuShumei
1K Followers 187 Following APPLETREE株式会社CEO https://t.co/HrlYlsz3Ah 【一家に一台の3Dプリンター時代を切り開く】
Hao Zhao @HaoZhao_AIRSUN
1K Followers 542 Following https://t.co/l52lTpdO16 Computer vision is good, have fun.
Grace Zhang @GZinMetaverse
2K Followers 604 Following Building the data backbone for physical AI, backed by @fdotinc, Electrical Eng @UBC
金沢工業大学ロ... @yumerobopro
3K Followers 678 Following 金沢工業大学 夢考房ロボットプロジェクトTeam_Robocon公式 Mail : [email protected] 活動の様子:#今日のロボプロ #金沢工業大学 #KIT夢考房 #夢考房 #学生ロボコン #ロボコン #SRC
孔明@B-SKY Lab @eternalfriend17
3K Followers 3K Following 趣味だったロボット屋さん/ #ドミネーター開発記録/ #バーサライターブレード/ #HecateII_CoilGun/ #bsl_snake/ #bsl_balancer/ #bsl_droid/ #スタックチャン/ #スネークチャン/ #タイリンチャン/ 青き民(寄りの箱)/ いのりまち町民/ 堕落した粗雑な暮らしYou might like

















